PLC vs DCS: Key Differences and How to Choose
This guide compares PLC vs DCS architecture, scan times, redundancy, scalability, programming, costs, and applications to help you choose the right industrial control system.

Last updated on 23 Sep, 2026. 18 minutes read
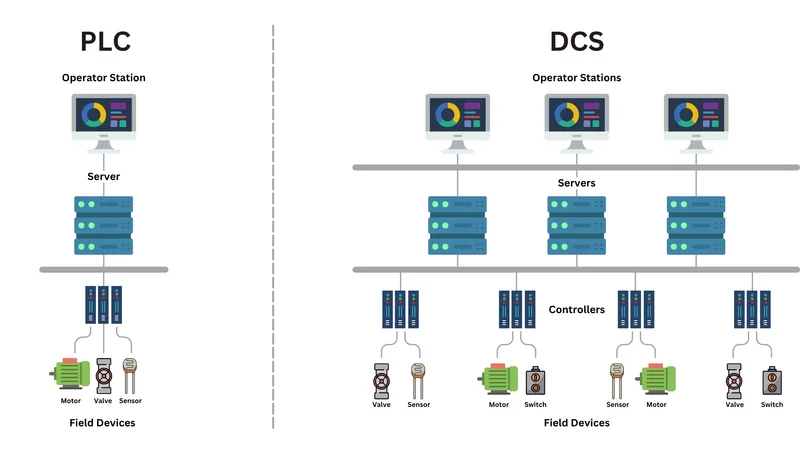
Programmable Logic Controller (PLC) vs Distributed Control System (DCS)
Key Takeaways
Definition – The programmable logic controller (PLC) is a solid-state control system with user-programmable memory for I/O control, logic, timing, counting, and three-mode PID control. The distributed control system (DCS) is a control architecture that layers supervisory control over a group of localized controllers.
Scope and Operational Extent – The real split is scope, not silicon: PLCs commonly act as the primary controller in smaller configurations that lack a central control server or HMI, whereas a DCS provides supervisory control over an entire production process.
Scan Time and Loop Execution – Timing ranges overlap far more than folklore admits: a Logix 5000 periodic task is configurable from 0.1 ms to 2,000 s (10 ms default), while DeltaV control modules are scheduled between 25 ms and 60 seconds.
Redundancy and High Availability – Redundancy is no longer a DCS-only feature; Siemens quotes fail-over times of 300 ms or 50 ms for its redundant S7-1500 R/H CPU pairs, depending on the optical or bus link utilized.
System Sizing and I/O Boundaries – I/O count provides a clear decision trigger for architecture choice, with industrial systems sizing PlantPAx deployments as small (under 2,000 I/O), medium (2,000 to 10,000 I/O), or large (10,000+ I/O).
Introduction
If you ask engineers about PLC vs DCS, you will often get an answer from 1995: PLCs are fast and cheap, a DCS is redundant and expensive, and the line between them is obvious. That framing has not held up over the last two decades of industrial automation. Modern process controllers accept periodic scan rates in the tens of milliseconds, modern PLCs ship with synchronized redundant CPUs, and at least one major distributed control system runs on a controller family that the same vendor also uses for discrete and motion applications.
The useful PLC vs DCS comparison must consider control speed, system architecture, redundancy, scalability, engineering workflows, cybersecurity, maintenance, and total lifecycle cost. It should also account for process criticality, operator needs, regulatory requirements, and future expansion. Understanding PLC vs DCS capabilities helps engineers avoid overengineering, reduce integration risks, and select a platform suited to operational priorities.
This article examines the essential distinctions, practical trade-offs, and decision criteria needed to approach PLC vs DCS selection with clarity and confidence across modern industrial automation environments.
What Is a PLC?
Programmable Logic Controller (PLC) is a solid-state control system with user-programmable memory for storing instructions to implement functions such as I/O control, logic, timing, counting, three-mode (PID) control, communication, arithmetic, and data and file processing. [1] This definition focuses on the device, not the plant around it.
The PLC exists because relay panels did not scale. Modicon created the first programmable logic controller in the United States in 1968, after Bedford Associates won a proposal to replace hard-wired relay systems with an electronic one. [2] Ladder logic, the idiom most closely associated with PLC programming, is modeled on the relay ladder diagrams it replaced.
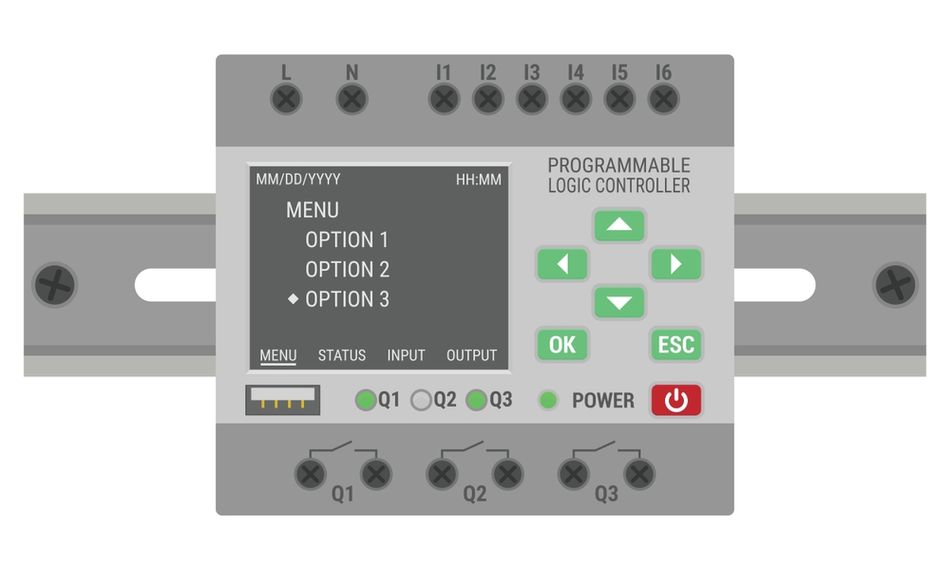
In practice, a PLC combines a central processing unit, power supplies, and digital and analog I/O modules in a rack or on a DIN rail. It reads discrete and analog signals from sensors, executes user logic, and drives actuators, typically with minimal human involvement in the loop.
Crucially, a PLC is not confined to standalone duty. PLCs are used in both SCADA and DCS systems as control components in an overall hierarchical system, locally managing processes through feedback control. In a DCS, PLCs serve as local controllers within a supervisory control scheme.
Recommended Reading: What is PLC? An Integral Component of Industrial Automation
What Is a DCS?
Distributed Control System (DCS) is an architecture rather than a box. DCS uses a central supervisory loop to oversee and mediate localized field controllers managing specific processes. This architecture integrates multiple subsystems across an entire production process while minimizing the impact of single faults. [1]
The supervisory layer sends set points to the distributed field controllers and requests data from them, while those controllers drive their process actuators based on control server commands and sensor feedback. Modularizing the production system this way reduces the impact of a single fault on the overall system.
Industries that use distributed control systems include oil refineries, water and wastewater treatment, electric power generation, chemical manufacturing, automotive production, and pharmaceutical processing. These are usually process control or discrete part control systems. Automotive production appears on that list, which is a useful correction to the idea that a DCS only runs continuous processes.
Most field devices sit on fieldbus networks. This eliminates the need for point-to-point wiring between a controller and individual field sensors and actuators, and it can also carry device diagnostics and execute control algorithms in the field.
Recommended Reading: What is a Distributed Control System (DCS)?
The Difference Between PLC and DCS: Architecture First
To better understand the key structural differences between PLC and DCS architectures, consider the following comparison table:
| Feature | PLC (Programmable Logic Controller) | DCS (Distributed Control System) |
| Control Distribution | Centralized | Distributed |
| Processor Configuration | Single or Redundant | Multiple, Distributed |
| I/O Handling | Local and Remote I/O | Distributed I/O Modules |
| Communication | Point-to-Point, Bus | Network-Based, Redundant |
| Scalability | Limited by Central Processor | Highly Scalable |
| Typical Application Size | Small to Medium | Medium to Large |
| Data Management | Local Data Storage | Centralized Historian |
| Human-Machine Interface | Basic HMI Capabilities | Advanced SCADA Integration |
| Typical Applications | Machine Control, Batch Processes | Continuous Processes, Large-Scale Plants |
Both architectures have their strengths and limitations. Below are the pros and cons for each:
PLC Architecture
The PLC-based topology is a controller plus whatever you build around it.
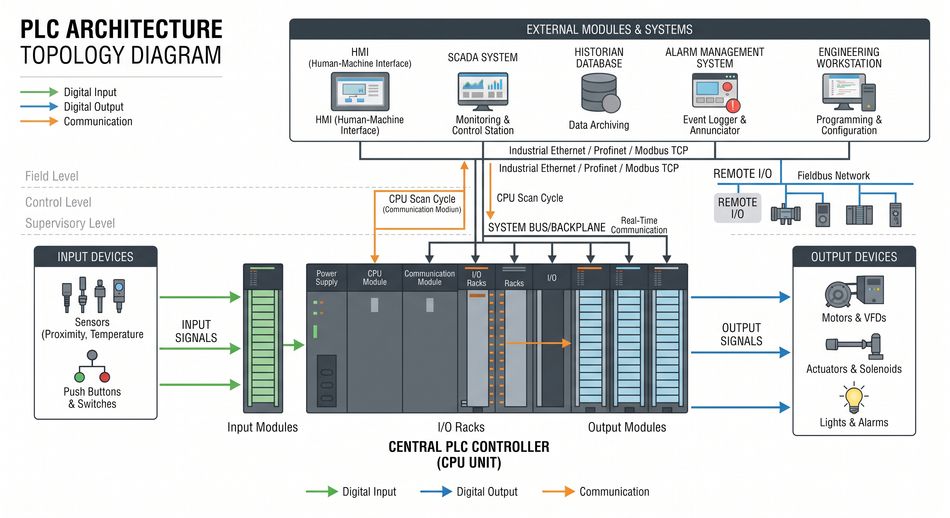
PLC topologies differ from SCADA and DCS in that they generally lack a central control server or HMI and, therefore, primarily provide closed-loop control with minimal human involvement. If you want operator graphics, alarm management, a historian or batch execution, you specify, license and integrate each of them.
Pros:
Rapid Scan Times and Response: Efficiently handles high-speed I/O and control loops.
Intuitive Programming: User-friendly programming environments for faster development and troubleshooting.
Cost-Effective for Smaller Systems: Lower initial investment for standalone applications.
Rugged and Reliable: Designed for harsh industrial environments.
Cons:
Limited Scalability: Challenges in expanding to large-scale, complex processes.
Less Suitable for Complex Process Control: May struggle with intricate control algorithms and advanced process optimization.
Single Point of Failure Risk: Reliance on a central controller can impact system uptime.
Basic Data Handling: Limited capabilities for advanced data analysis and reporting.
DCS Architecture
DCS is the surrounding infrastructure, sold and engineered as one system.
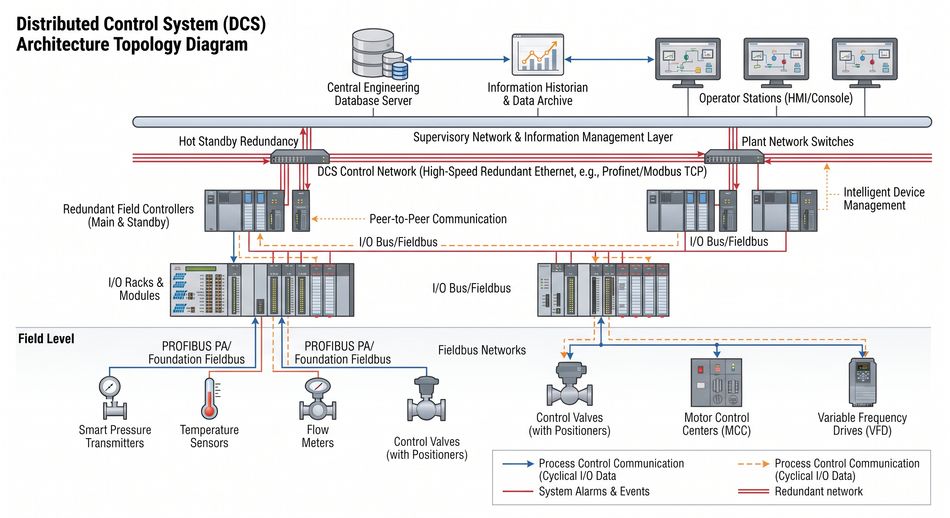
The supervisory level, the operator workstations, the engineering database, and the field controllers are designed to work together. That is generally why a DCS costs more up front and removes integration work that a PLC project has to absorb.
Pros:
Ideal for Large-Scale Processes: Handles complex, distributed systems with numerous control loops.
High Scalability and Flexibility: Easily expandable to accommodate growing process requirements.
Built-in Redundancy: Ensures continuous operation and fault tolerance.
Advanced Data Management: Comprehensive data acquisition, analysis, and visualization.
Cons:
Higher Initial Investment: Requires substantial upfront costs for hardware and software.
Slower Response Times for Discrete Control: Not optimal for high-speed, discrete applications.
Complex Engineering: Requires specialized expertise for system configuration and maintenance.
Vendor Lock-In: Tight integration with specific DCS platforms can limit flexibility.
By carefully considering these factors, engineers can make informed decisions about the most suitable architecture for their specific application.
Recommended Reading: Mastering Distributed Control Systems: Comprehensive Guide to DCS Architecture, Components, and Applications
Component Breakdown
Programmable Logic Controllers (PLCs) and Distributed Control Systems (DCS) are composed of distinct components that work together to provide effective control solutions. To better understand the differences between PLC and DCS systems, examine their core components and how they interact.
PLC Components:
Central Processing Unit (CPU): The brain of the PLC, executing the control program and managing system operations.
Power Supply: Provides the electrical power the PLC and its components need.
Input/Output (I/O) Modules: Interface between the PLC and field devices, converting signals between digital/analog and the PLC's internal format.
Communication Module: Enables connectivity with other PLCs, HMIs, and higher-level systems.
Memory: Stores the control program, data, and configuration settings.
Programming Device: Typically, a computer is used to develop and upload the control program.
In a PLC system, the CPU repeatedly scans inputs, executes the control program, and updates outputs.
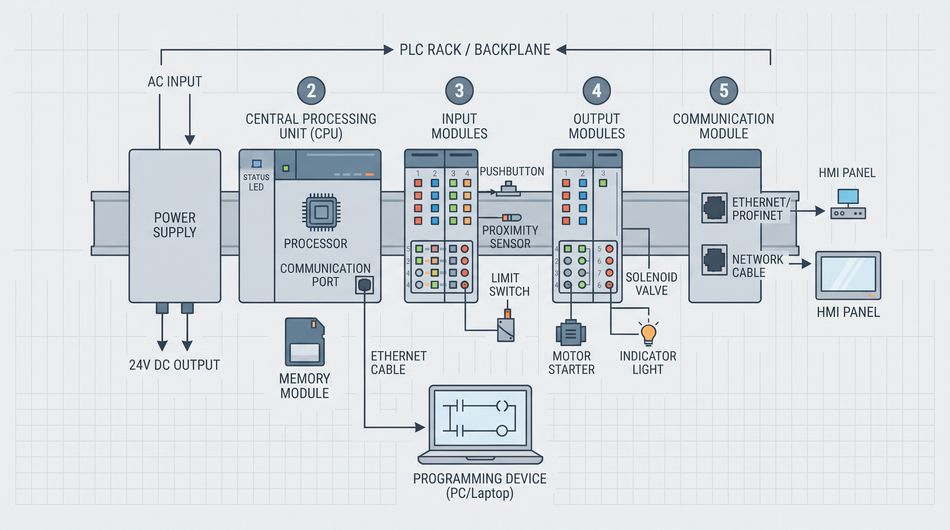
The power supply ensures stable operation, while I/O modules convert signals. The communication module facilitates data exchange with other systems, and the memory retains crucial information for continuous operation.
DCS Components:
Controllers: Distributed processors handling specific process areas or functions.
I/O Subsystems: Decentralized modules for signal acquisition and control output.
Human-Machine Interface (HMI): Operator workstations for process monitoring and control.
Engineering Workstations: Used for system configuration, programming, and maintenance.
Historian: Database for long-term storage of process data and events.
Communication Network: High-speed, redundant networks connecting all DCS components.
Field Devices: Sensors, actuators, and other process instruments.
In a DCS, controllers operate autonomously within their assigned areas and communicate via the network. [2]
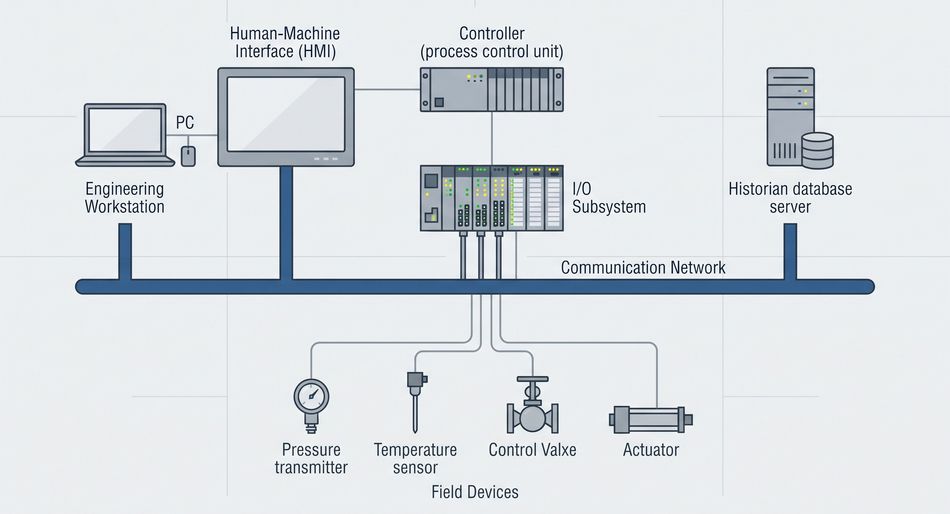
I/O subsystems distribute data acquisition and control closer to the process. HMIs provide operators with real-time information and control, while engineering workstations enable system-wide configuration. The historian captures and stores data for analysis and reporting.
Let’s understand it better using a diagram of PLC and DCS system structures:
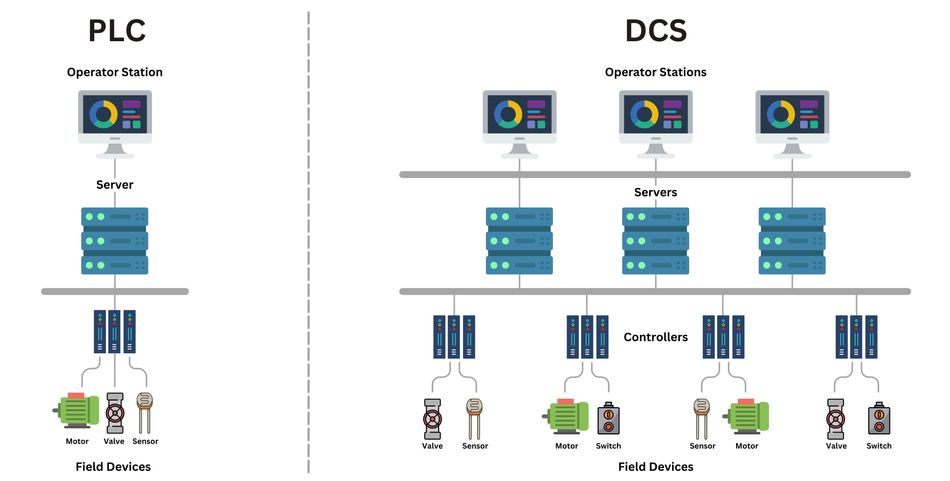
In a PLC, all components are closely integrated with the central CPU. In contrast, a DCS uses multiple controllers interconnected via a network, with distributed I/O subsystems and various workstations for different functions.
Recommended Reading: HMI Technologies: The Ultimate Guide to Human-Machine Interface Innovations
Response Time and Scan Rates
On the PLC side, a Logix 5000 controller supports multiple tasks to schedule and prioritize the running of your programs based on specific criteria. [4]
Continuous Task: Runs in the background on whatever CPU time is not allocated to motion, communication or other tasks, and restarts immediately when it completes a full scan.
Periodic Task: Interrupts any lower-priority task, runs once, returns control, and has a configurable period of "from 0.1 ms…2000 s," with a default of 10 ms.
Event Task: Runs only when a trigger occurs, such as a change in a digital input, a new analog sample, or an EVENT instruction.
On the DCS side, DeltaV control modules are automatically scheduled by the controller, based on their assigned scan rates, and those module scan times can be set as fast as 25 ms and as slow as 60 seconds. [5] The published execution rates are 25 ms, 50 ms, 100 ms, 200 ms, 500 ms, 1 s, 2 s, 5 s, 10 s, 30 s and 60 s.
This leads to two key conclusions: First, a modern DCS is not slow: a 25 ms floor is generally fast enough for regulatory control loops such as temperature, level, and flow. Second, the PLC advantage at the fast end is real but narrow, since 0.1 ms only buys you something where the application genuinely needs it, typically fast interlocks, motion coordination and high-speed discrete control.
The more consequential difference is who decides. On a PLC, you architect the task structure yourself and carry the consequences of getting priorities wrong. On a DCS, the controller schedules modules for you based on the scan rate you assign, trading some control for much more consistency across a large configuration.
Programming: Ladder Logic, Function Block Diagrams and Structured Text
Both platforms draw on the same standard. IEC 61131-3 specifies the syntax and semantics of programming languages for programmable controllers as defined in IEC 61131-1. Edition 4.0, published on 22 May 2025, lists Structured Text as the textual language, Ladder Diagram and Function Block Diagram as the graphical languages, and Sequential Function Chart for organizing program execution. [3]
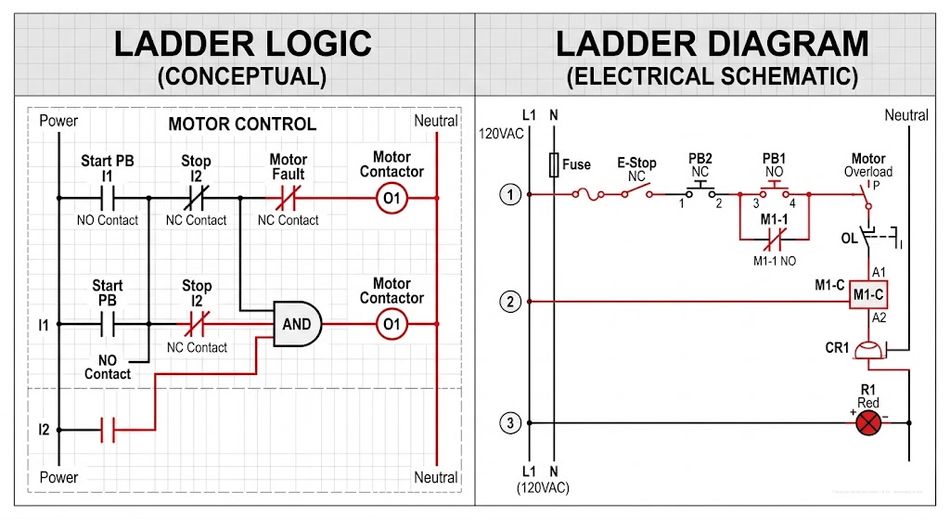
PLC work commonly gravitates to ladder logic, because discrete control maps cleanly onto rungs of contacts and coils, and because a maintenance technician can read a ladder rung on a panel HMI at 3 AM. The structured text, one textual and high-level programming language in the current edition, tends to be reserved for algorithms, string handling and data manipulation that ladder expresses badly.
DCS work commonly gravitates toward function block diagrams and continuous function charts (CFC), a vendor idiom rather than an IEC 61131-3 language. The process loop is naturally a graph of signal flow, transmitter to PID block to valve, and that representation also matches how a DCS library is built: reusable, pre-tested blocks that you instance rather than rewrite.
IEC 61131-3 still describes two textual languages, including Instruction List alongside Structured Text.
Recommended Reading: PLC Programming: Languages, Scan Cycles, and Working Ladder Logic
Redundancy and Availability
The old rule was that a DCS gives you redundancy and a PLC does not. That rule is now wrong in both directions, and the interesting question is what high availability costs you.
In a DCS, it is a licensed configuration option rather than a bespoke design. The DeltaV controller redundancy is defined as a standby controller that contains the same control strategies as the active controller, with a link that transfers control parameters so it is ready to take over. The pair continuously monitor themselves and each other for conditions that require a switchover, and a hard failure of the active controller triggers an immediate switchover. Transfer is designed to be bumpless, with output channels holding their states until the switchover completes and control modules begin executing. [6]
That capability is not free. The additional operations typically reduce your CPU free time by about 10%, and a license is required in addition to the standby hardware. The two controllers must also be of the same series.
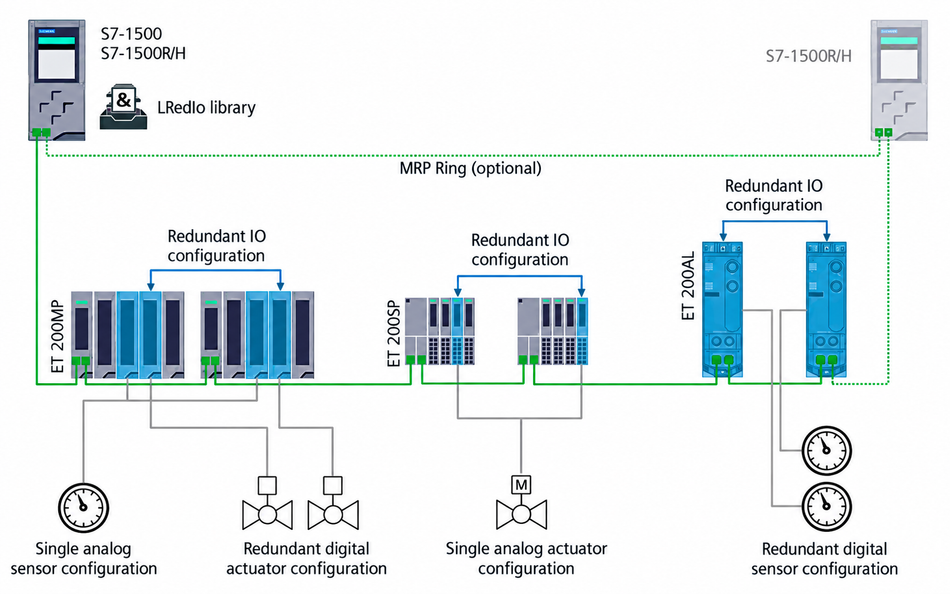
On the PLC side, Siemens sells high availability as a standard CPU variant. In an S7-1500 R/H pair, one CPU serves as primary and the other as backup; the roles can change during operation, and both execute the user program in parallel so that if one fails, the second maintains control of the process. [8] The system automatically feeds the backup the same program and synchronously monitors the primary CPU in operation. [7] Siemens quotes a fail-over time of 300 ms or 50 ms, depending on whether the pair is linked over PROFINET or over synchronization modules and fiber-optic cable.
This also has a networking cost: for R-CPUs, the redundancy connections consume part of the PROFINET bandwidth for synchronisation, which is then unavailable for PROFINET I/O communication. [8]
In short, both platforms offer a standby controller. DCS more often bundles fault tolerance across several layers at once, including networks, servers and power supplies, engineered and tested as a set rather than assembled per project.
Scalability and System Size
Scalability is where the decision usually resolves itself, and Rockwell - PlantPAx sizing gives you an unusually explicit yardstick. Its selection guide splits architectures into small (under 2,000 I/O), medium (2,000 to 10,000 I/O) and large (10,000 or more I/O). [9]
Crossing those thresholds has concrete consequences. The small architectures are specified with 1 to 5 Compact or ControlLogix controllers. For medium and large systems, there is no hard limit to the number of controllers, with the count per data server depending on controller selection, controller loading and the number of operator workstations. Operator seats scale the same way: a single consolidated server supports a maximum of 10 operator workstation clients, while the distributed architectures can have as many as 120. [9]
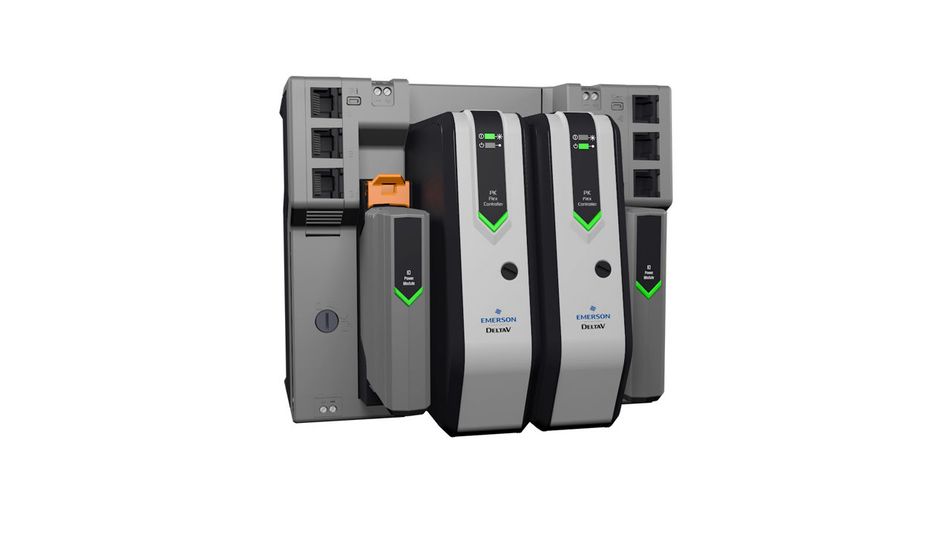
DCS controllers publish similar ceilings. The DeltaV PK controller is offered with DST limits of 100, 300, 750 or 1500, and supports up to 8 carriers of 8 cards each, for a total of 64 traditional I/O cards. [5]
The takeaway is that PLC-based system architecture scales by adding controllers you then have to coordinate, while DCS architecture scales by adding controllers into an existing coordination scheme. Below a couple of thousand I/O, that coordination is overhead. Well above it, building it yourself is the expensive option.
Recommended Reading: What Is a Programmable Automation Controller (PAC)?
Integration and Connectivity: From Shop Floor to Top Floor
Network Protocols and Communication
Industrial control systems rely on robust communication protocols to ensure seamless data exchange between various components and higher-level systems. PLCs and DCS systems use a range of protocols, each tailored to specific industrial communication needs.
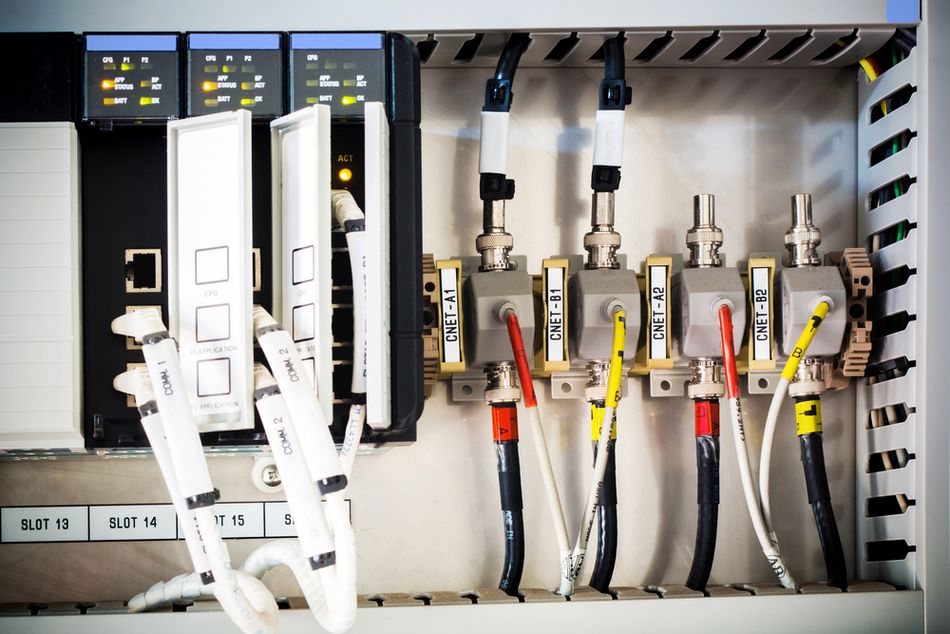
Common communication protocols in PLC systems include:
Modbus: A simple, open protocol widely used for device-to-device communication.
EtherNet/IP: Based on standard Ethernet, it's popular for its compatibility with IT infrastructure.
Profinet: Developed by Siemens, it offers real-time capabilities for industrial automation.
DeviceNet: A CAN-based protocol for connecting industrial devices.
OPC UA: A platform-independent protocol for secure data exchange.
DCS systems often utilize more advanced protocols, including:
Foundation Fieldbus: Designed for process control applications, offering deterministic communication.
HART (Highway Addressable Remote Transducer): Enables digital communication over existing 4- 20 mA analogue wiring.
Profibus: A Fieldbus protocol for high-speed data communication in process automation.
OPC UA: Increasingly adopted in DCS for interoperability and security.
Proprietary Protocols: Many DCS vendors offer their own optimized communication protocols.
Integration with higher-level systems differs between PLCs and DCS:
PLC Integration:
PLCs often require additional middleware or OPC servers to connect with SCADA systems.
Integration with MES (Manufacturing Execution Systems) typically involves custom programming or third-party software.
Data historians may need separate configurations to collect data from multiple PLCs.
DCS Integration:
DCS platforms usually offer built-in SCADA functionality, eliminating the need for separate systems.
MES integration is often more streamlined, with DCS providing direct interfaces or pre-built connectors.
Historian capabilities are typically integrated into the DCS architecture, making data collection and analysis easier.
PLC systems often require intermediate layers for higher-level integration. DCS system, by contrast, provide a more integrated approach with built-in plant-wide control and data management.
Recommended Reading: Modbus TCP: A Comprehensive Guide to the Protocol and Its Applications
Where Each One Fits?
Match the platform to the process, not to the industry label.
Choose a PLC when the work is discrete manufacturing or machine control: assembly, packaging, material handling, presses, robotic cells and skids. The automobile assembly lines are a fine example of a PLC operating as the primary controller in a smaller configuration. [1] Fast interlocks, motion coordination and self-contained equipment that ships to a customer all favor a PLC.
Choose a DCS when you are running continuous processes across a plant with operators on shift. The municipal water treatment works and an oil refinery look nothing alike chemically, yet they land in the same column here. The tell is not the process chemistry but the operating model: many loops, long campaigns, alarms a human must triage, and a control room that never closes.
Batch processing sits in between, and it is the case where a DCS earns its keep for reasons that have nothing to do with scan rates. The stated scope of ISA-88 is to provide guidelines for the design and specifications of batch control systems, separating a physical model that relates control equipment and data communications from a functional model covering recipe management, scheduling, sequential control, regulatory control and safety interlock systems. [10] Recipe management on top of a bare PLC is a project. On a DCS, it is usually a product.
The alarm handling follows the same logic. ANSI/ISA-18.2-2016 frames alarm management as a full lifecycle, from initial identification and rationalization to implementation, maintenance and ongoing change management, anchored in a documented alarm philosophy. DCS ships with the machinery for that lifecycle. On a PLC project, you assemble it.
PLC vs DCS vs SCADA
SCADA is a third category, not a subtype of either, and mixing it up with the other two is the most common conceptual error in this comparison.
Supervisory Control and Data Acquisition Systems (SCADA) control dispersed assets where centralized data acquisition is as important as control, across distribution systems such as water distribution and wastewater collection, oil and natural gas pipelines, electrical transmission and distribution, and rail and other public transportation. [1] Typical SCADA hardware is a control server at a control center, communications equipment, and geographically distributed field sites made up of remote terminal units or PLCs.
The distinguishing variable is geography. DCS controls production systems within the same geographic location. SCADA systems control dispersed assets, and do so under conditions where acquiring the data reliably matters as much as issuing the control.
So SCADA is neither a PLC nor a DCS. It is a supervisory layer that often sits above PLCs, which is exactly why the question keeps coming up.
The ISA-95 hierarchy is a cleaner way to keep all three in your head: Level 0 is physical production processes, Level 1 is sensing and manipulating the production process, Level 2 is monitoring and supervising control, Level 3 is manufacturing operations management, and Level 4 is business planning and logistics.
PLCs live at Level 1, while SCADA and DCS supervisory functions live at Level 2.
Recommended Reading: PLC and SCADA: Understanding the Differences in Industrial Automation Systems
Is the PLC Becoming Obsolete? The Convergence Case
No, and the strongest evidence is what DCS vendors are shipping!
PlantPAx is sold as a PlantPAx Distributed Control System, and its selection guide states that "the ControlLogix and CompactLogix controllers support continuous process and batch applications" and that "these controllers also support discrete and motion applications." [9] The same controller family that handles the discrete and motion work is the control layer of the distributed control system.
The convergence runs the other way as well. The DeltaV PK controller, a DCS controller, natively supports Modbus TCP, EtherNet/IP, PROFINET, and an OPC UA server, which is the protocol set you would expect on a PLC. [5]
Practically, this means PLC or DCS is less and less a hardware question and increasingly a question of the engineering and operations model you are buying: libraries, templates, alarm handling, change management, operator tooling, and lifecycle support. Industrial automation industry vendors have converged the controller, but they have not converged anything above it.
How to Choose: Practical Sequence
Below are the design considerations for industrial control systems; in fact, the factors that drive control, communication, reliability and redundancy decisions. Work through them in this order:
Establish the Safety Case: Systems must detect unsafe conditions and trigger actions to reduce them to safe ones, and most safety-critical operations require human oversight of potentially dangerous processes. Settle this before comparing controllers.
Characterize the Timing Requirement: Processes have a wide range of time-related requirements, including very high speed, consistency, regularity, and synchronization. Separate the few loops that genuinely need single-digit milliseconds from the many that do not.
Measure the Geographic Distribution: The small system (e.g., local PLC-controlled process) scales to large, distributed systems (e.g., oil pipelines, electric power grids). Once assets span vast distances, SCADA is the appropriate architecture rather than relying solely on controller selection.
Count the I/O and the Operator Seats: Use the sizing tiers above: under 2,000 I/O and a handful of controllers is PLC-and-HMI territory; 10,000 or more I/O with dozens of operator seats is not.
Set the Availability Target: High availability targets may require more redundancy or alternative implementations across all communications and controls. Then price redundancy on both platforms, including the CPU and bandwidth overheads quoted above. [6][8]
Assess the Operating Model: Consider who runs this at 3 AM, how many alarms they will see, whether recipes change weekly, and who owns changes five years from now. This question decides more DCS purchases than scan time does.
Recommended Reading: The Engineer's Guide to Industrial IoT and Industry 4.0
Common Mistakes
Comparing Purchase Price instead of Total Engineered Cost: The PLC quotation may exclude supervisory software, historian functionality, alarm management, and integration work that a DCS package includes. Compare equivalent system scopes.
Assuming a DCS cannot perform Discrete Control: Modern DCS platforms can manage both continuous processes and discrete production operations.
Assuming a PLC cannot provide Redundancy: Many industrial PLC platforms support synchronized redundant processors, communication networks, power supplies, and I/O arrangements. [7]
Specifying the fastest Scan Rate: Assign execution rates according to process needs. Running slow loops at unnecessarily fast rates consumes controller capacity without improving performance.
Buying a DCS for an Independent Skid: The self-contained machine maintained locally may be better served by a PLC and HMI than plant-wide DCS infrastructure.
Underestimating Lifecycle Overheads: Redundancy consumes processing capacity, network bandwidth, engineering time, testing effort, and maintenance resources. Include these costs when evaluating both architectures.
Conclusion
The PLC vs DCS decision is no longer a simple choice between speed and reliability. Modern PLCs can support redundancy, process control, and large architectures, while DCS platforms increasingly handle discrete operations and integrate industrial communication protocols.
The meaningful differences lie in system scope, engineering model, operator requirements, scalability, and lifecycle management. PLCs remain well suited to machines, skids, high-speed interlocks, and smaller control systems. DCS platforms are stronger when many controllers, process loops, alarms, recipes, and operator stations must function as one coordinated environment.
Consider SCADA separately when assets are geographically dispersed. Before selecting a platform, define safety, timing, I/O, availability, operational, and maintenance requirements. The best solution is the architecture that meets those needs without creating unnecessary complexity or lifecycle cost.
Frequently Asked Questions
Q. What is the main difference between PLC and DCS?
A. PLC is a controller; a DCS is an architecture. DCS is a control architecture with a supervisory level overseeing multiple integrated sub-systems, using a centralized supervisory control loop to mediate localized controllers. PLC topologies, by contrast, generally lack a central control server or HMI and mainly provide closed-loop control with minimal human involvement.
Q. Is SCADA a PLC or a DCS?
A. Neither. SCADA is a supervisory layer for dispersed assets where centralized data acquisition matters as much as control, and its field sites typically consist of remote terminal units or PLCs. DCS, by contrast, controls production systems within a single geographic location.
Q. Is DCS better than PLC?
A. Only for the problems a DCS is shaped for: plant-wide process control with operators on shift, many loops, batch recipes and formal alarm management. For machine control, skids and discrete manufacturing, a DCS is expensive overhead. Size the I/O and describe the operating model before deciding.
Q. Can a PLC replace a DCS?
A. For smaller process industry plants, often yes, provided you budget for the supervisory layer: HMI, alarm management, historian, batch execution and change control. That software and integration work is what you are actually buying when you buy a DCS.
Q. Is a DCS faster than a PLC?
A. Not usually at the fast end. DeltaV control modules run between 25 ms and 60 seconds, while a Logix 5000 periodic task can be configured from 0.1 ms to 2000 s. For regulatory loops, the difference is irrelevant; for motion and fast interlocks, it is not.
Q. Which languages do PLCs and a DCS use?
A. Both draw on IEC 61131-3, whose edition 4.0 lists Structured Text, Ladder Diagram, Function Block Diagram and Sequential Function Chart. PLC work leans on ladder logic and Structured Text; DCS work leans on function block diagrams and continuous function charts.
Q. Do I need redundancy?
A. Only if the availability requirement justifies it. Redundancy is often tied to systems with strong availability and up-time requirements. Price it properly: DeltaV redundancy typically costs about 10% of controller CPU free time plus a license, and Siemens R-CPU redundancy consumes PROFINET bandwidth.
References
[1] NIST. Guide to Operational Technology (OT) Security [Cited 2026 September 20] Available at: Link
[2] Schneider Electric. Modicon is now Schneider Electric [Cited 2026 September 20] Available at: Link
[3] IEC. IEC 61131-3:2025, Programmable controllers, Part 3: Programming languages [Cited 2026 September 20] Available at: Link
[4] Rockwell Automation. Logix 5000 Controllers Tasks, Programs, and Routines [Cited 2026 September 20] Available at: Link
[5] Emerson. DeltaV PK Controller Product Data Sheet [Cited 2026 September 20] Available at: Link
[6] Emerson. DeltaV Controller Redundancy Product Data Sheet [Cited 2026 September 20] Available at: Link
[7] Siemens. SIMATIC S7-1500 R/H CPUs [Cited 2026 September 20] Available at: Link
[8] Siemens. S7-1500R/H Redundant System, System Manual A5E41814787-AA [Cited 2026 September 20] Available at: Link
[9] Rockwell Automation. PlantPAx Distributed Control System Selection Guide [Cited 2026 September 20] Available at: Link
[10] ISA. ISA88 Committee: Batch Control [Cited 2026 September 20] Available at: Link
in this article
1. Key Takeaways2. Introduction3. What Is a PLC?4. What Is a DCS?5. The Difference Between PLC and DCS: Architecture First6. Response Time and Scan Rates7. Programming: Ladder Logic, Function Block Diagrams and Structured Text8. Redundancy and Availability9. Scalability and System Size10. Integration and Connectivity: From Shop Floor to Top Floor11. Where Each One Fits?12. PLC vs DCS vs SCADA13. Is the PLC Becoming Obsolete? The Convergence Case14. How to Choose: Practical Sequence15. Common Mistakes16. Conclusion17. Frequently Asked Questions18. References